What i want to achieve
I want when the player is hit by the tool they are flung and ragdolled
The Problem
View the Scripts
ServerScriptForRagdoll
local BreakJointsOnDeath = true
–[[-----------------------------------------------------------]]local player = script.Parent.Parent.Parent
local character = player.Character
local humanoid = character.Humanoid–character:WaitForChild(“Humanoid”)
humanoid.BreakJointsOnDeath = BreakJointsOnDeathlocal variables = script.Parent.variables–script.Parent:WaitForChild(“variables”)
local variables_ragdoll = variables.ragdoll–variables:WaitForChild(“ragdoll”)local events = script.Parent.events–script.Parent:WaitForChild(“events”)
local events_variableserver = events.variableserver–events:WaitForChild(“variableserver”)local functions = script.Parent.functions–script.Parent:WaitForChild(“functions”)
local functions_remoteragdoll = functions.remoteragdoll–functions:WaitForChild(“remoteragdoll”)
local functions_remoteragdollvelocity = functions.remoteragdollvelocity–functions:WaitForChild(“remoteragdollvelocity”)
local functions_ragdoll = functions.ragdoll–functions:WaitForChild(“ragdoll”)local PhysicsService = game:GetService(“PhysicsService”)
local Debris = game:GetService(“Debris”)local constraintfolder = character:FindFirstChild(“RagdollConstraints”)
if not constraintfolder then constraintfolder = Instance.new(“Folder”,character); constraintfolder.Name = “RagdollConstraints” end
local collisionfolder = character:FindFirstChild(“CollisionConstraints”)
if not collisionfolder then collisionfolder = Instance.new(“Folder”,character); collisionfolder.Name = “CollisionConstraints” endlocal noclipgrouptest = pcall(function() PhysicsService:GetCollisionGroupId(“noclip”) end)
if not noclipgrouptest then
PhysicsService:CreateCollisionGroup(“noclip”)
PhysicsService:CollisionGroupSetCollidable(“Default”,“noclip”,false)
endlocal bodyparts = {
HumanoidRootPart = character:WaitForChild(“HumanoidRootPart”);LowerTorso = character:WaitForChild(“LowerTorso”);
LeftUpperLeg = character:WaitForChild(“LeftUpperLeg”);
LeftLowerLeg = character:WaitForChild(“LeftLowerLeg”);
LeftFoot = character:WaitForChild(“LeftFoot”);RightUpperLeg = character:WaitForChild(“RightUpperLeg”);
RightLowerLeg = character:WaitForChild(“RightLowerLeg”);
RightFoot = character:WaitForChild(“RightFoot”);UpperTorso = character:WaitForChild(“UpperTorso”);
LeftUpperArm = character:WaitForChild(“LeftUpperArm”);
LeftLowerArm = character:WaitForChild(“LeftLowerArm”);
LeftHand = character:WaitForChild(“LeftHand”);RightUpperArm = character:WaitForChild(“RightUpperArm”);
RightLowerArm = character:WaitForChild(“RightLowerArm”);
RightHand = character:WaitForChild(“RightHand”);Head = character:WaitForChild(“Head”);
}local motors = {
Root = bodyparts.LowerTorso:WaitForChild(“Root”);LeftHip = bodyparts.LeftUpperLeg:WaitForChild(“LeftHip”);
LeftKnee = bodyparts.LeftLowerLeg:WaitForChild(“LeftKnee”);
LeftAnkle = bodyparts.LeftFoot:WaitForChild(“LeftAnkle”);RightHip = bodyparts.RightUpperLeg:WaitForChild(“RightHip”);
RightKnee = bodyparts.RightLowerLeg:WaitForChild(“RightKnee”);
RightAnkle = bodyparts.RightFoot:WaitForChild(“RightAnkle”);Waist = bodyparts.UpperTorso:WaitForChild(“Waist”);
LeftShoulder = bodyparts.LeftUpperArm:WaitForChild(“LeftShoulder”);
LeftElbow = bodyparts.LeftLowerArm:WaitForChild(“LeftElbow”);
LeftWrist = bodyparts.LeftHand:WaitForChild(“LeftWrist”);RightShoulder = bodyparts.RightUpperArm:WaitForChild(“RightShoulder”);
RightElbow = bodyparts.RightLowerArm:WaitForChild(“RightElbow”);
RightWrist = bodyparts.RightHand:WaitForChild(“RightWrist”);Neck = bodyparts.Head:WaitForChild(“Neck”);
}local constraints = {
Ankle = Instance.new(“BallSocketConstraint”);
Elbow = Instance.new(“HingeConstraint”);
Hip = Instance.new(“BallSocketConstraint”);
Knee = Instance.new(“HingeConstraint”);
Neck = Instance.new(“BallSocketConstraint”);
Shoulder= Instance.new(“BallSocketConstraint”);
Waist = Instance.new(“BallSocketConstraint”);
Wrist = Instance.new(“BallSocketConstraint”);
}constraints.Ankle.LimitsEnabled = true
constraints.Ankle.TwistLimitsEnabled = true
constraints.Ankle.UpperAngle = 30
constraints.Ankle.TwistLowerAngle = -45
constraints.Ankle.TwistUpperAngle = 30constraints.Elbow.LowerAngle = 0
constraints.Elbow.UpperAngle = 135
constraints.Elbow.LimitsEnabled = trueconstraints.Hip.LimitsEnabled = true
constraints.Hip.TwistLimitsEnabled = true
constraints.Hip.UpperAngle = 50
constraints.Hip.TwistLowerAngle = 100
constraints.Hip.TwistUpperAngle = -45constraints.Knee.LowerAngle = -140
constraints.Knee.UpperAngle = 0
constraints.Knee.LimitsEnabled = trueconstraints.Neck.LimitsEnabled = true
constraints.Neck.TwistLimitsEnabled = true
constraints.Neck.MaxFrictionTorque = 4
constraints.Neck.UpperAngle = 60
constraints.Neck.TwistLowerAngle = -75
constraints.Neck.TwistUpperAngle = 60constraints.Shoulder.LimitsEnabled = true
constraints.Shoulder.TwistLimitsEnabled = true
constraints.Shoulder.UpperAngle = 45
constraints.Shoulder.TwistLowerAngle = -90
constraints.Shoulder.TwistUpperAngle = 150constraints.Waist.LimitsEnabled = true
constraints.Waist.TwistLimitsEnabled = true
constraints.Waist.UpperAngle = 30
constraints.Waist.TwistLowerAngle = -55
constraints.Waist.TwistUpperAngle = 25constraints.Wrist.LimitsEnabled = true
constraints.Wrist.TwistLimitsEnabled = true
constraints.Wrist.UpperAngle = 30
constraints.Wrist.TwistLowerAngle = -45
constraints.Wrist.TwistUpperAngle = 45function toggleMotors(mode) ------------------- FUNCTION ------------------
for i,v in pairs(motors) do
if i ~= “Root” then
v.Enabled = mode
end
end
endlocal orgrootmotor = motors.Root
local altrootmotor = Instance.new(“Motor6D”,bodyparts.UpperTorso)
altrootmotor.C0 = CFrame.new(0,(bodyparts.LowerTorso.Size.Y)*0.7,0)
altrootmotor.Enabled = false
altrootmotor.Part0 = bodyparts.HumanoidRootPart
altrootmotor.Part1 = bodyparts.UpperTorsofunction ragdollJoint(part0, part1, attachmentName) ----------------------Function 2-----------
local constraintname
for i,v in pairs(constraints) do
if string.match(attachmentName,i) then
constraintname = i
break
end
end
attachmentName = attachmentName..“RigAttachment”
local constraint = constraints[constraintname]:Clone()
constraint.Attachment0 = part0[attachmentName]
constraint.Attachment1 = part1[attachmentName]
constraint.Name = “Ragdoll_”..part1.Nameconstraint.Parent = constraintfolder
endpcall(ragdollJoint,bodyparts.LowerTorso, bodyparts.UpperTorso, “Waist”)
pcall(ragdollJoint,bodyparts.UpperTorso, bodyparts.Head, “Neck”)
pcall(ragdollJoint,bodyparts.UpperTorso, bodyparts.LeftUpperArm, “LeftShoulder”)
pcall(ragdollJoint,bodyparts.UpperTorso, bodyparts.RightUpperArm, “RightShoulder”)pcall(ragdollJoint,bodyparts.LeftUpperArm, bodyparts.LeftLowerArm, “LeftElbow”)
pcall(ragdollJoint,bodyparts.RightUpperArm, bodyparts.RightLowerArm, “RightElbow”)pcall(ragdollJoint,bodyparts.LeftLowerArm, bodyparts.LeftHand, “LeftWrist”)
pcall(ragdollJoint,bodyparts.RightLowerArm, bodyparts.RightHand, “RightWrist”)pcall(ragdollJoint,bodyparts.LowerTorso, bodyparts.LeftUpperLeg, “LeftHip”)
pcall(ragdollJoint,bodyparts.LowerTorso, bodyparts.RightUpperLeg, “RightHip”)pcall(ragdollJoint,bodyparts.LeftUpperLeg, bodyparts.LeftLowerLeg, “LeftKnee”)
pcall(ragdollJoint,bodyparts.RightUpperLeg, bodyparts.RightLowerLeg, “RightKnee”)pcall(ragdollJoint,bodyparts.LeftLowerLeg, bodyparts.LeftFoot, “LeftAnkle”)
pcall(ragdollJoint,bodyparts.RightLowerLeg, bodyparts.RightFoot, “RightAnkle”)function getAccessoryAttachment0(name) ------Function 3--------
for _,v in pairs(character:GetChildren()) do
local attachment = v:FindFirstChild(name)
if attachment then return attachment end
end
endfunction makeaccessoryjoints() ---------Function 4---------
for ,v in pairs(character:GetChildren()) do
if v:IsA(“Accessory”) then
local handle = v:FindFirstChild(“Handle”)
if handle then
handle.CustomPhysicalProperties = PhysicalProperties.new(0,0,0,0,0)
local attachment1 = handle:FindFirstChildOfClass(“Attachment”)
local attachment0 = getAccessoryAttachment0(attachment1.Name)
if attachment1 and attachment0 then
local con = Instance.new(“HingeConstraint”)
con.Name = "Accessory"..v.Name
con.Attachment0 = attachment0
con.Attachment1 = attachment1
con.LimitsEnabled = true
con.UpperAngle = 0
con.LowerAngle = 0
con.Parent = constraintfolder
end
end
end
end
endmakeaccessoryjoints()
bodyparts.HumanoidRootPart.CanCollide = false
bodyparts.HumanoidRootPart.CustomPhysicalProperties = PhysicalProperties.new(0,0,0,0,0)
bodyparts.Head.CustomPhysicalProperties = PhysicalProperties.new(0,0,0,0,0)
bodyparts.Head.OriginalSize.Value = Vector3.new(1,1,1)
bodyparts.Head.Size = Vector3.new(bodyparts.Head.Size.Z,bodyparts.Head.Size.Y,bodyparts.Head.Size.Z)local HeadCollision = Instance.new(“Part”,bodyparts.Head)
HeadCollision.Name = “HeadCollision”
HeadCollision.Transparency = 1
HeadCollision.Parent = bodyparts.Head
HeadCollision.Shape = Enum.PartType.Cylinder
local headsize = bodyparts.Head.Size
HeadCollision.Size = Vector3.new(headsize.Y,headsize.Z,headsize.Z)
HeadCollision.CanCollide = true
bodyparts.Head:GetPropertyChangedSignal(“Size”):Connect(function()
local headsize = bodyparts.Head.Size
HeadCollision.Size = Vector3.new(headsize.Y,headsize.Z,headsize.Z)
end)local HeadCollisionWeld = Instance.new(“Weld”,HeadCollision)
HeadCollisionWeld.Part0 = bodyparts.Head
HeadCollisionWeld.Part1 = HeadCollision
HeadCollisionWeld.C0 = HeadCollisionWeld.C0*CFrame.fromOrientation(0,0,math.rad(-90))PhysicsService:SetPartCollisionGroup(bodyparts.Head,“noclip”)
local HeadCollisionAttachment = Instance.new(“Attachment”,HeadCollision)
HeadCollisionAttachment.Orientation = Vector3.new(0,0,-90)local HeadCollisionConstraint = Instance.new(“HingeConstraint”)
HeadCollisionConstraint.Name = “HeadCollision”
HeadCollisionConstraint.Attachment0 = bodyparts.Head.FaceCenterAttachment
HeadCollisionConstraint.Attachment1 = HeadCollisionAttachment
HeadCollisionConstraint.LimitsEnabled = true
HeadCollisionConstraint.UpperAngle = 0
HeadCollisionConstraint.LowerAngle = 0
HeadCollisionConstraint.Parent = constraintfolderlocal collisionfiltertbl = {
{
HeadCollision;bodyparts.LeftUpperArm; bodyparts.LeftUpperLeg; bodyparts.LowerTorso; bodyparts.RightUpperArm; bodyparts.RightUpperLeg; bodyparts.UpperTorso;};
{
bodyparts.LeftFoot;bodyparts.LowerTorso; bodyparts.UpperTorso;};
–[[{
bodyparts.LeftHand;--bodyparts.LowerTorso; bodyparts.UpperTorso;};]]
{
bodyparts.LeftLowerArm;bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.LeftLowerLeg;bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.LeftUpperArm;bodyparts.LeftUpperLeg; bodyparts.LowerTorso; bodyparts.RightUpperArm; bodyparts.RightUpperLeg; bodyparts.UpperTorso;};
{
bodyparts.LeftUpperLeg;bodyparts.LowerTorso; bodyparts.RightUpperLeg; bodyparts.UpperTorso;};
{
bodyparts.RightFoot;bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.RightHand;--bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.RightLowerArm;bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.RightLowerLeg;bodyparts.LowerTorso; bodyparts.UpperTorso;};
{
bodyparts.RightUpperArm;bodyparts.LeftUpperLeg; bodyparts.LowerTorso; bodyparts.LeftUpperArm; bodyparts.RightUpperLeg; bodyparts.UpperTorso;};
{
bodyparts.RightUpperLeg;bodyparts.LowerTorso; bodyparts.LeftUpperLeg; bodyparts.UpperTorso;};
}function makecollisionfilters() ----------- Function 5 -----------
for i=1,#collisionfiltertbl do
for b=2,#collisionfiltertbl[i] do
local constraint = Instance.new(“NoCollisionConstraint”,collisionfolder)
constraint.Name = collisionfiltertbl[i][1].Name..“<->”..collisionfiltertbl[i][b].Name
constraint.Part0 = collisionfiltertbl[i][1]
constraint.Part1 = collisionfiltertbl[i][b]
end
end
endmakecollisionfilters()
local isragdollnow = false
function ragdoll(mode,velocity)
if mode == true then
if isragdollnow then
if velocity then
functions_remoteragdollvelocity:InvokeClient(player,velocity)
end
return
end
isragdollnow = true
variables_ragdoll.Value = true
altrootmotor.Enabled = true
orgrootmotor.Enabled = false
toggleMotors(false)
functions_remoteragdoll:InvokeClient(player,true,velocity)
–wait()elseif mode == “dead” then
if flag_clonecharacter then
player.CharacterRemoving:Connect(function()
character.Archivable = true
pcall(function() bodyparts.UpperTorso.radio.Sound:Destroy() end)
local clone = character:Clone()
clone.Name = player.Name..“'s Ragdoll”
for _,v in pairs(clone:GetDescendants()) do
if v:IsA(“BaseScript”) then
v:Remove()
end
end
for _,v in pairs(character:GetChildren()) do
if not v:IsA(“Humanoid”) then
v:Remove()
end
end
clone.Parent = workspace
clone.Humanoid.Health = 1
clone.Humanoid.Health = 0
if flag_autocleanup and flag_cleanuptime then
Debris:AddItem(clone,flag_cleanuptime)
end
pcall(function()
for _,v in pairs(clone:GetChildren()) do
if v:IsA(“BasePart”) then
v:SetNetworkOwnershipAuto()
end
end
end)
end)
end
else
if not isragdollnow then
return
end
isragdollnow = false
orgrootmotor.Enabled = true
altrootmotor.Enabled = false
toggleMotors(true)
functions_remoteragdoll:InvokeClient(player,false)
end
endhumanoid.Died:Connect(function()
ragdoll(true)
ragdoll(“dead”)
print(“YES”)
end)–variables_ragdoll:GetPropertyChangedSignal(“Value”):Connect(function()
– if humanoid.Health > 0 then ragdoll(variables_ragdoll.Value) ragdoll(“dead”) end
–end)events_variableserver.OnServerEvent:Connect(function(plr,variable,mode)
if variable == “reset” then
humanoid.Health = 0
else
ragdoll(mode)
ragdoll(“dead”)
–pcall(function() variables[variable].Value = mode end)
end
end)function functions_ragdoll.OnInvoke(velocity)
ragdoll(true,velocity)
endfunction functions_remoteragdoll.OnServerInvoke(plr)
ragdoll(true)
end
Script for Knockbacktool
local hitCooldown = false
local RagdollScript = game.ServerScriptService.RagdollScriptscript.Parent.Activated:Connect(function()
if hitCooldown then return end
hitCooldown = true
local ray = Ray.new(script.Parent.Parent.HumanoidRootPart.Position, script.Parent.Parent.HumanoidRootPart.Position + script.Parent.Parent.HumanoidRootPart.CFrame.LookVector * 10)
local hit = workspace:FindPartOnRay(ray, script.Parent.Parent)
if hit then
  local humanoid = hit.Parent:FindFirstChild("Humanoid")

  if humanoid then

  	humanoid.Parent.HumanoidRootPart.AssemblyLinearVelocity = script.Parent.Parent.HumanoidRootPart.CFrame.LookVector * 200 + Vector3.new(0, 100, 0)
  	require(RagdollScript)
  end
end
task.wait(1)
hitCooldown = false
end)
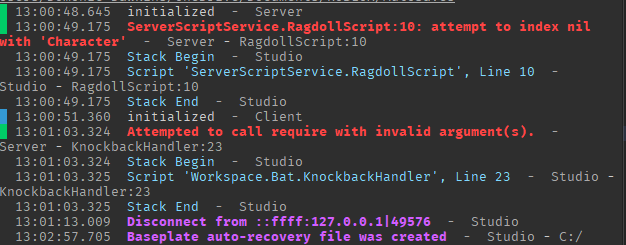
Ouput Errors